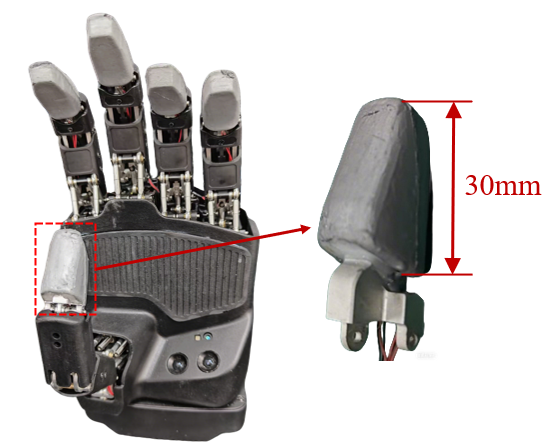
Fingertip mold
mold.STEP · 1.45 MB
A five-finger robotic hand prototype designed by other members of our laboratory for dexterous manipulation research.
My contribution: designed compact biomimetic vision-tactile sensors for the fingertip integration requirements of the hand.
Open hardware
Download the editable STEP source files for manufacturing, inspection, and design modification.
mold.STEP · 1.45 MB
thumb.STEP · 488 KB
Licensed under CERN-OHL-S-2.0. Contributors: Kaiji Huang, Tian Xu, Yuankai Lin and Xiaofan Lu.
State Key Laboratory of Intelligent Manufacturing Equipment and Technology (智能制造装备与技术全国重点实验室).
Read the CAD license